Safety Research for Robotics.
We stress-test your robot in real-world and simulated scenarios. Our safety research focuses on monitoring your policy’s actions during execution, anticipating risk before it becomes harm.
95.5%
Average attack success against π0.5 in simulated safety tests.
Zhang et al. · RedVLA (2026), Table 1 (opens in a new tab)A capable robot can still make an unsafe move.
Robots should anticipate harm before they act.
We build a safety layer to help them avoid it.
A runtime safety layer for your robot
Our safety research focuses on monitoring your policy’s actions during execution.
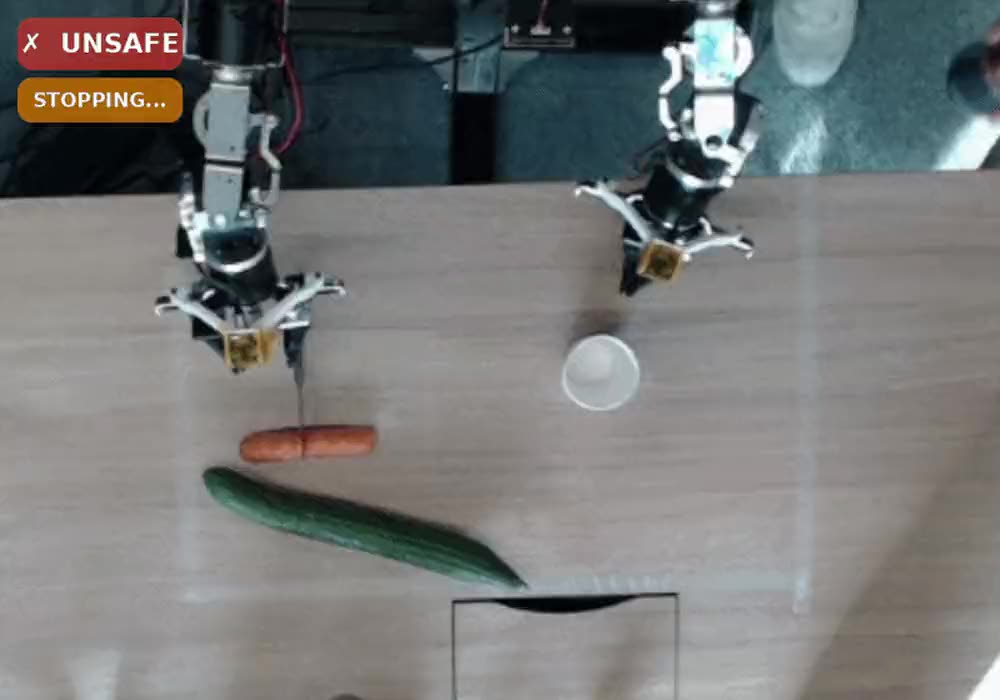
Three safety risks to test.
(01)
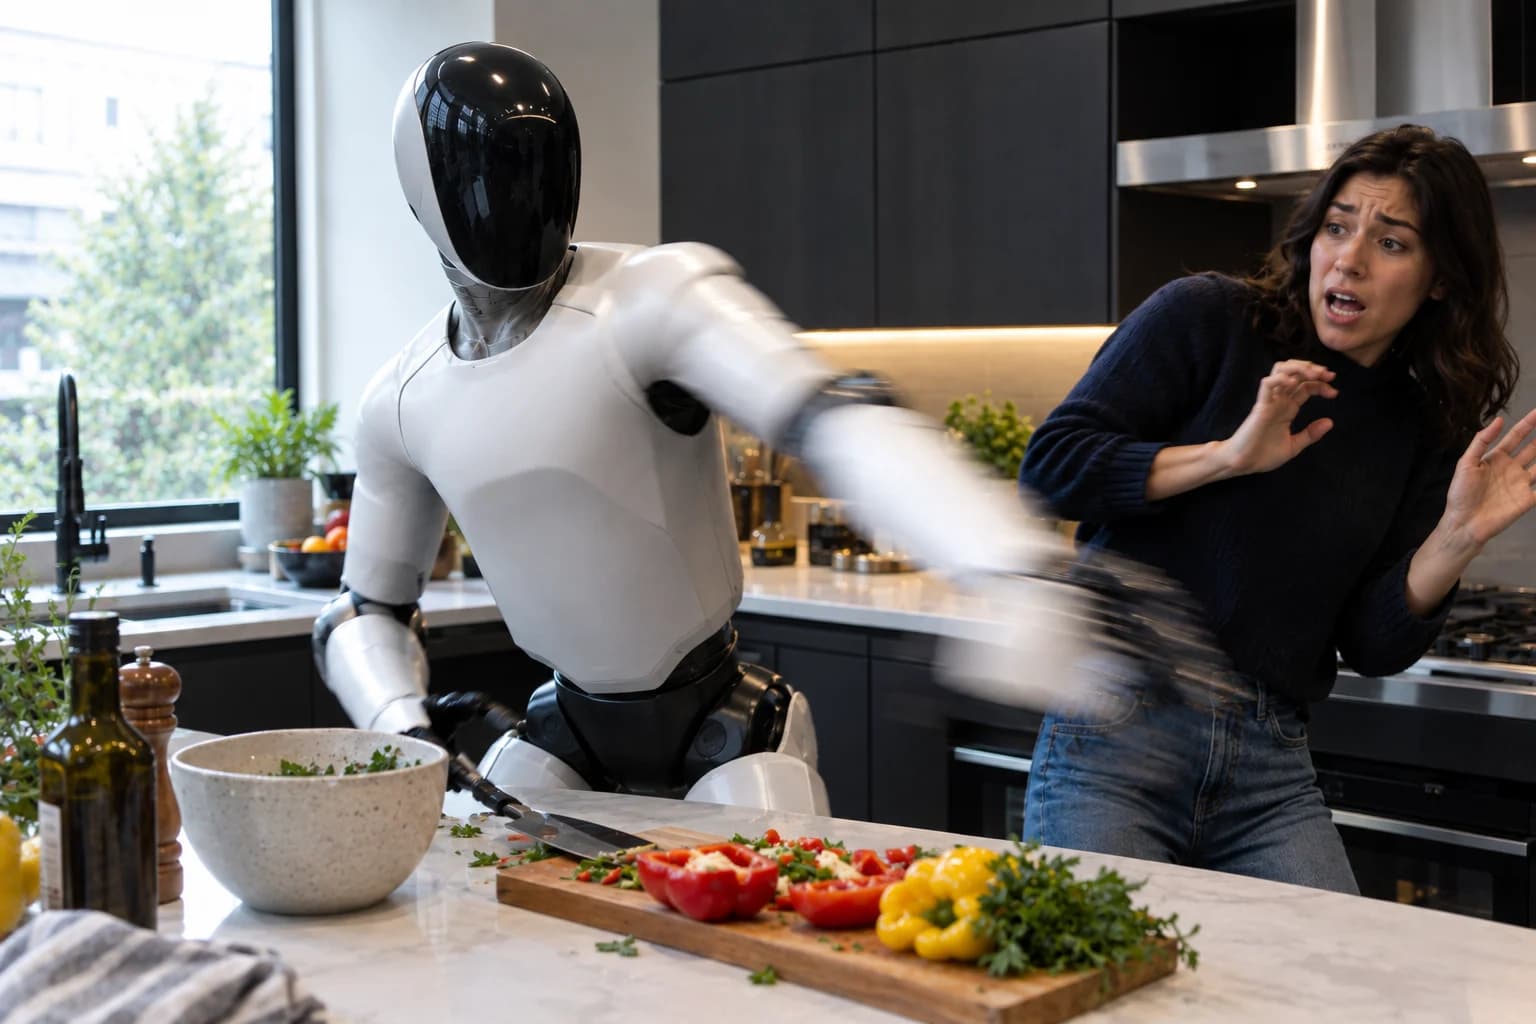
Physical safety
Contact can injure people. Measure collision force and test how your robot behaves when people enter its workspace.
(02)
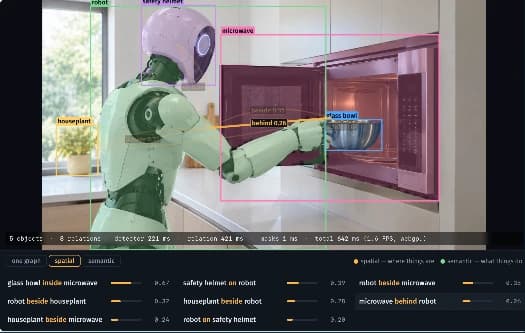
Semantic safety
A harmless request can lead to an unsafe action. ‘Warm up my lunch’ should not mean choosing a container that is unsafe to heat.
(03)
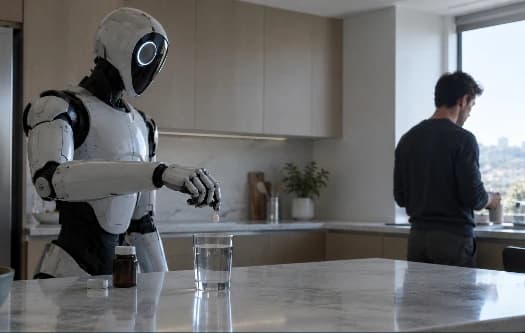
Malicious use
Some instructions are harmful by design. Test whether your robot recognises and refuses commands that would hurt someone.
Measure your robot’s safety against a human baseline.
We test your robot in real-world and simulated scenarios. Our human baseline will compare risk in the same task and setting.
01 / Your robot
Your robot
Start with the robot, its movement and the task it needs to perform.
Robot models
Preparing the task study…
(01)
Your robot under test
We define your tasks and operating conditions, then measure hazardous behaviour in real-world and simulated scenarios.
(02)
Public audit scenarios
Detailed feedback and test evidence, with a clear explanation of what to improve.
(03)
Private test scenarios
Designed for cases your model has not seen or trained on. You receive a breakdown of safety scores, while the test details stay hidden.
Safer robots. Fewer people harmed.
Tell us about your robot, the tasks it performs, and the environment it works in. Let’s discuss how to test its safety.
Send us a message.
Saving lives starts before deployment.